Robotics
How Many Trials Back a Force-Aware Manipulation Claim?
A statistical audit of 2026 real-robot evaluations
Clement Nana Aidoo
53%
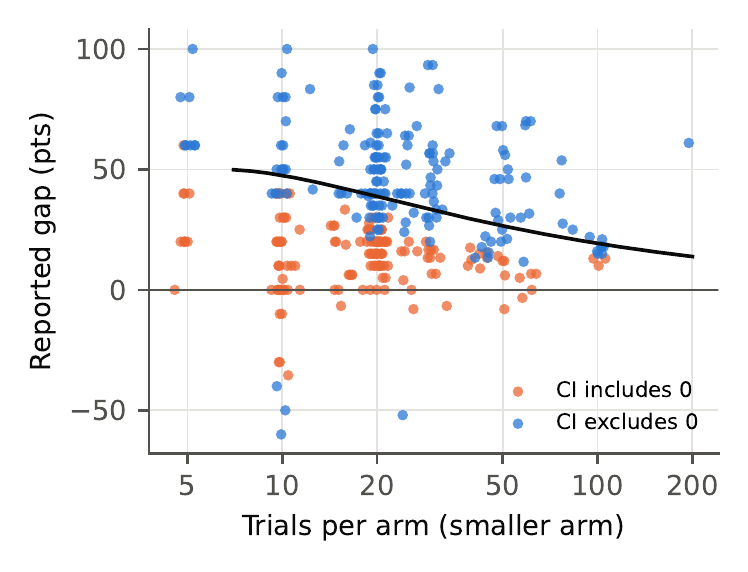
Share of comparisons whose 95% interval for the difference excluded zero, although the proposed method scored higher in 91% of them
Summary
Papers on force-aware manipulation usually support their claims with real-robot success rates measured over a handful of trials. We audited how much statistical evidence those numbers carry, following a protocol frozen before any data were extracted.
Our summary. The archived abstract is the authority: doi:10.31224/8576.
What it found
- F1
We screened 89 arXiv papers, included 58, and extracted 377 binary comparisons of the proposed method against its strongest baseline or its own ablation.
- F2
The median condition was evaluated on 20 trials (interquartile range 15–30). Only 17% of papers reported any interval or error bar on success.
- F3
Only 6% of comparisons had 80% power to detect a true 20-point improvement. Two equally good methods compared on 10 trials each show an apparent gain of 10 points or more 41% of the time.
Limitations
- None of this says the methods do not work: most reported gaps are large and in the expected direction.
- Extraction was done by instances of an AI assistant. A second, blinded extraction checked the data, and the author re-coded a seeded random 20% of papers by hand (19 of 19 inclusion decisions and 100% of 88 binary rows matched).
- A revision is in progress.
Cite
@misc{aidoo2026trialaudit,
  title  = {How Many Trials Back a Force-Aware Manipulation Claim? A Statistical Audit of 2026 Real-Robot Evaluations},
  author = {Aidoo, Clement Nana},
  year   = {2026},
  note   = {engrXiv preprint, version 2},
  doi    = {10.31224/8576},
  url    = {https://doi.org/10.31224/8576}
}Evidence chain
01 · Claim
53%
02 · Figure
03 · Code
04 · Archive
Code and data
Corrections and open questions
- Still openThe trial-count audit is being revised