Robotics
Motor-current sensorless slip and contact detection
Clement Nana Aidoo
0.031 rad
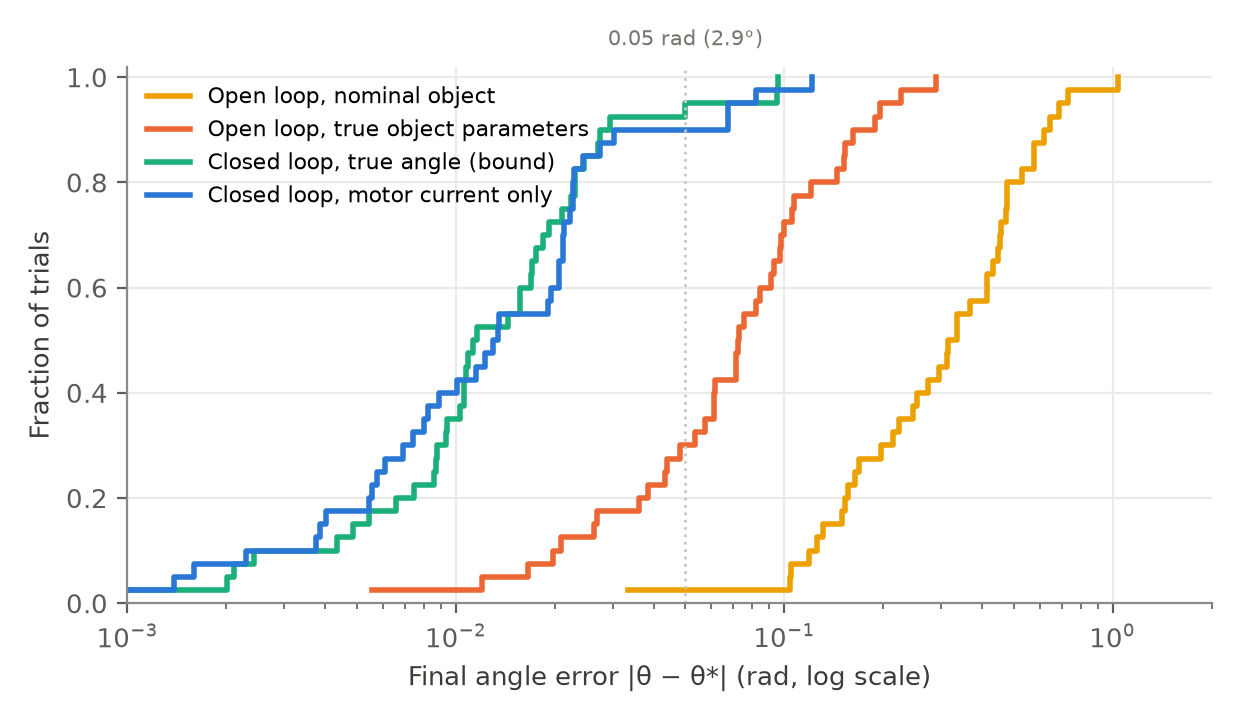
RMS final angle error pivoting 40 randomised objects with motor current only, against 0.107 rad for open loop given the true object parameters (simulation)
Summary
Gravitational pivoting lets a parallel-jaw gripper reorient an object by loosening its grip. Published controllers watch the object with tactile sensors or cameras. We ask whether the motor current of the wrist actuator is enough.
Our summary. The archived abstract is the authority: doi:10.5281/zenodo.23264189.
Archived title: Gravity Pivoting from Motor Current: Calibration-Free Angle Estimation and the Sensing Budget It Requires
What it found
- F1
A slow downhill sweep of the wrist angle followed by a linear least-squares fit recovered the direction of the object’s centre of mass to 0.009 rad RMS across 100 randomised objects with ideal sensing.
- F2
Through a modelled current-sensing chain the estimate stayed at 0.0093–0.0094 rad for gearbox friction up to 0.1 N·m, while a single static current reading degraded from 0.088 to 1.39 rad.
- F3
In closed loop, 90.0% of pivots landed within 0.05 rad, against 0.413 rad RMS error for an open-loop schedule given one nominal set of parameters.
Limitations
- All results are from simulation.
- Torque observes the centre-of-mass direction rather than the object’s geometric axis.
- A wrist motion made while the grip is loose ratchets the object downward, and the controller needs about 16.6 probes per pivot.
Cite
@misc{aidoo2026motorcurrent,
  title  = {Motor-current sensorless slip and contact detection},
  author = {Aidoo, Clement Nana},
  year   = {2026},
  note   = {engrXiv preprint},
  doi    = {10.5281/zenodo.23264189},
  url    = {https://doi.org/10.5281/zenodo.23264189}
}Evidence chain
01 · Claim
0.031 rad
02 · Figure
03 · Code
04 · Archive
Code and data