Robotics
Residual Pivoting
Faster search, and where the quasi-static model breaks
Clement Nana Aidoo
18.0 → 9.3
Measurements per pivot with a learned residual on the physics controller (40 held-out objects, simulation)
Summary
Our earlier pivoting controller measures the rod angle from wrist motor current and steps the grip force down with a quasi-static friction model. It is accurate but slow. Here we test whether a learned residual on top of it makes it faster. We measure the cost in accuracy and compare it with a policy learned without the model.
Our summary. The archived abstract is the authority: doi:10.5281/zenodo.23352629.
What it found
- F1
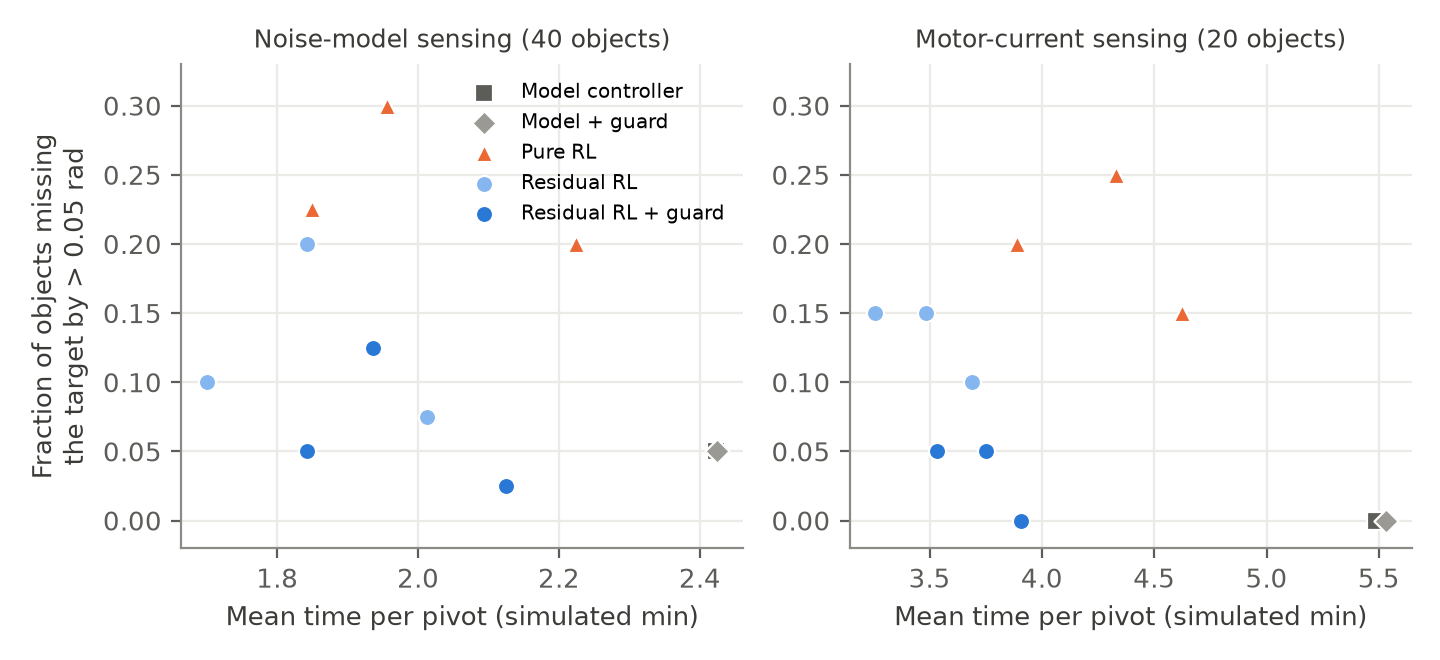
Residual policies cut pivot time by 24%, with almost all the saved steps in the search phase. They overshot the target more often: 88% against 95% of objects within 0.05 rad.
- F2
Most overshoots happened on one step: when the rod first slips it rotates in one jump, with a median of 0.46 rad.
- F3
A guard that bounds the search step brought accuracy back to the model controller’s level (93% within 0.05 rad) while keeping a 19% time saving. With the full motor-current sensing pipeline the guarded residual was 32% faster (3.73 against 5.49 simulated minutes) at 97% against 100% within 0.05 rad.
Limitations
- All results are from simulation.
- The guard was designed after we saw test results. It was confirmed once, on 40 fresh objects, where guarded policies reached 98, 95 and 90% within 0.05 rad against 95% for the model controller.
- One of three seeds stayed clearly worse with noise-model sensing.
Cite
@misc{aidoo2026residualpivoting,
  title  = {Residual Pivoting: Faster Search, and Where the Quasi-Static Model Breaks},
  author = {Aidoo, Clement Nana},
  year   = {2026},
  note   = {engrXiv preprint, version 2},
  doi    = {10.5281/zenodo.23352629},
  url    = {https://doi.org/10.5281/zenodo.23352629}
}Evidence chain
01 · Claim
18.0 → 9.3
02 · Figure
03 · Code
04 · Archive
Code and data
Corrections and open questions